Main Page   Namespace List   Class Hierarchy   Compound List   File List   Compound Members   File Members  

RRTPolar Class Reference

Gradually bias the sampling towards the goal. More...

#include <rrt.h>

Inheritance diagram for RRTPolar:
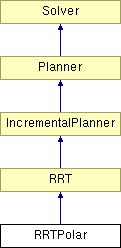
RRT IncrementalPlanner Planner Solver List of all members.

Public Methods

 RRTPolar (Problem *p)
virtual ~RRTPolar ()

Public Attributes

double RadiusExp

Protected Methods

virtual MSLVector ChooseState ()
 Pick a state using some sampling technique. More...

virtual MSLVector SelectInput (const MSLVector &x1, const MSLVector &x2, MSLVector &nx_best, bool &success)

Detailed Description

Gradually bias the sampling towards the goal.

Instead of random sampling, this planner attempts to gradually bias samples toward the goal.


Constructor & Destructor Documentation

RRTPolar::RRTPolar (  Problem *    p ) 
 

virtual RRTPolar::~RRTPolar (    )  [inline, virtual]


Member Function Documentation

MSLVector RRTPolar::ChooseState (    )  [protected, virtual]
 

Pick a state using some sampling technique.

Reimplemented from RRT.

MSLVector RRTPolar::SelectInput (  const MSLVector &    x1,
const MSLVector &    x2,
MSLVector &    nx_best,
bool &    success
)  [protected, virtual]


Member Data Documentation

double RRTPolar::RadiusExp


The documentation for this class was generated from the following files: Motion Strategy Library


Web page maintained by Steve LaValle